

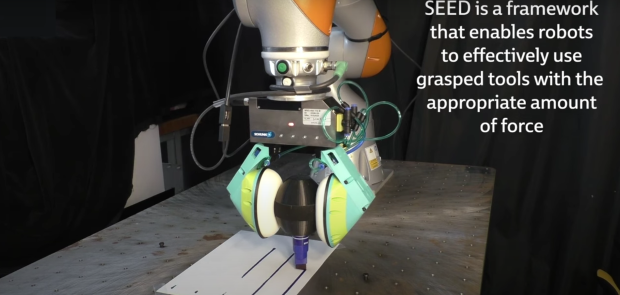



MIT researchers have developed a new soft robotics platform able to grip items such as tools using the appropriate amount of force. The Series Elastic End Effectors (SEED) has been designed to allow robots to carry out tasks that require the application of force of a grasped tool with proper pressure.
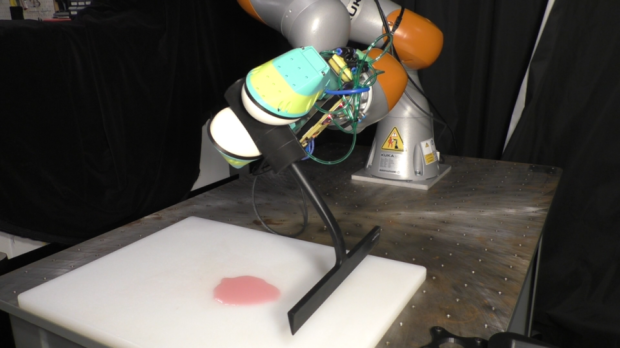
Robotic advancements are still ongoing, but traditional rigid robots still have difficulty completing tasks that are easy for humans. To complement robots, SEED uses embedded cameras and soft bubble grippers that use deformation that is carefully mapped. Everything the robot senses can be tracked in real-time in a 3D image that changes shape around a particular object that is being used - and each experience can be later utilized as a learned model.
SEED makes it possible for robots to successfully move objects with six degrees of freedom so it can move an object back and forth, up or down, left or right, roll, yaw, and pitch. Tasks demonstrated included how to set a screw to the proper torque, use a squeegee to clean up a spill, and write with a marker.
The MIT Computer Science and Artificial Intelligence Laboratory (CSAIL) worked with researchers from the Toyota Research Institute (TRI) to develop the SEED system.
"Nobody will be surprised that compliance can help with tools, or that force sensing is a good idea; the question here is where on the robot the compliance should go and how soft it should be. Here we explore regulating a quite-soft six degree-of-freedom stiffness directly at the hand/tool interface, and show that there are some nice advantages to do that."
Of course, there is still plenty of work left to be done, as the SEED system currently can only deal with specific tool geometry. The tool must be cylindrical, although future updates may support other shapes so a wider variety of tools can be supported.
MIT's SEED system in action: